- ev3dev version: 4.14.117-ev3dev-2.3.5-ev3
- ev3dev-lang-python version:
- ||/ Name Version Architecture Description
ii micropython-ev3dev2 2.1.0 all Python language bindings for ev3dev for MicroPython
ii python3-ev3dev 1.2.0 all Python language bindings for ev3dev
ii python3-ev3dev2 2.1.0 all Python language bindings for ev3dev
Hi,
I am using gyro and odometry with MoveDifferential.
tank_drive = MoveDifferential(OUTPUT_B,OUTPUT_C,Tire,WheelDistance)
tank_drive.odometry_start(0,xTank,yTank,sleep_time=0.005)
Command turn_left, turn_righ, on_for_distance, turn_degrees works correctly, when put angle -90 it turns left, angle 90 turns right.
But however if I issue command turn_to_angle and angle_target_degrees = 90 , use_gyto=True, it turns left, but gyro shows -90 also if I put -90 it turns right(gyro output 90), so opposite of what is expected.
Then on_to_coordinates is also opposite for left and right. It seems that coordinate system is with reverse y
.........................|+x
.................1......|..........2
+y------------------------- -y
.......................|
.......................| -x
as I put on_to_coordinates(speed, 200,200) it goes to pos 1, but should go to pos 2.
robot construction is similar to this :
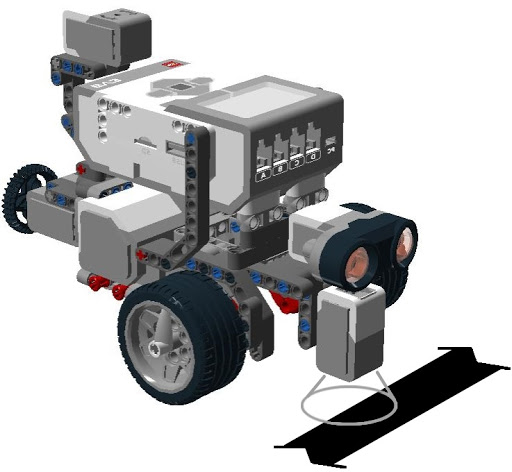
maybe there is wrong direction of motors?
ii micropython-ev3dev2 2.1.0 all Python language bindings for ev3dev for MicroPython
ii python3-ev3dev 1.2.0 all Python language bindings for ev3dev
ii python3-ev3dev2 2.1.0 all Python language bindings for ev3dev
Hi,
I am using gyro and odometry with MoveDifferential.
tank_drive = MoveDifferential(OUTPUT_B,OUTPUT_C,Tire,WheelDistance)
tank_drive.odometry_start(0,xTank,yTank,sleep_time=0.005)
Command turn_left, turn_righ, on_for_distance, turn_degrees works correctly, when put angle -90 it turns left, angle 90 turns right.
But however if I issue command turn_to_angle and angle_target_degrees = 90 , use_gyto=True, it turns left, but gyro shows -90 also if I put -90 it turns right(gyro output 90), so opposite of what is expected.
Then on_to_coordinates is also opposite for left and right. It seems that coordinate system is with reverse y
.........................|+x
.................1......|..........2
+y------------------------- -y
.......................|
.......................| -x
as I put on_to_coordinates(speed, 200,200) it goes to pos 1, but should go to pos 2.
robot construction is similar to this :

maybe there is wrong direction of motors?