Skip to content
View berito's full-sized avatar

Block or report berito

Block user

Prevent this user from interacting with your repositories and sending you notifications. Learn more about blocking users.

You must be logged in to block users.

Content in all repositories owned by your account will be closed.
Maximum 250 characters. Please don’t include any personal information such as legal names or email addresses. This note will only be visible to you.
Report abuse

Contact GitHub support about this user’s behavior. Learn more about reporting abuse.

Report abuse
berito/README.md

Hi, I'm Mohammed

Robotics Engineer | SLAM, Navigation, Computer Vision | ROS 2, C++, Python

MSc Assistant Lecturer Experience

YouTube Upwork LinkedIn

Focus areas

Computer Vision / Perception

Object detection and tracking, segmentation, multi-sensor fusion and real-time inference.

SLAM and State Estimation

LiDAR and visual-inertial SLAM, pose-graph optimization, sensor fusion and calibration.

Robotics and Robot Learning

Navigation, motion planning and control for mobile robots, and robot learning.

Projects

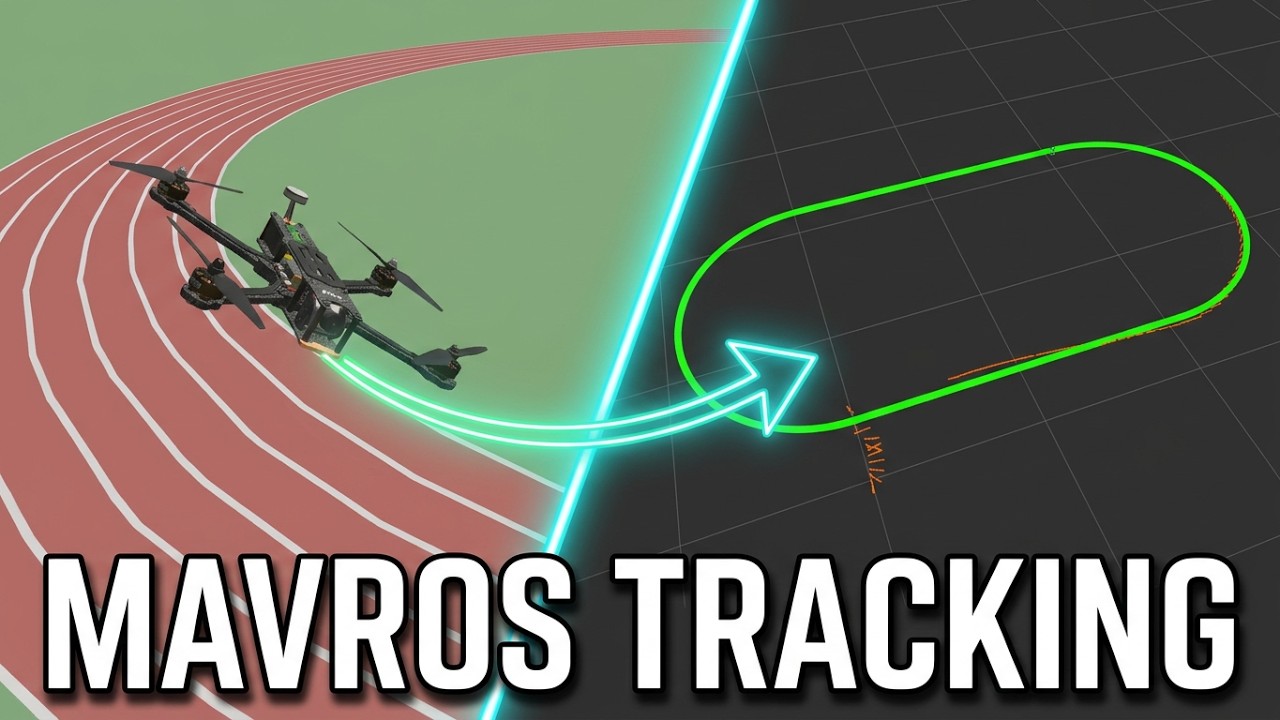
PX4 track pacing

PX4 track pacing

Robotics Simulation ROS 2 PX4 MAVROS Gazebo Harmonic

A drone flies autonomous laps of a running track, with trajectory, speed and altitude set in a config file.

Result: laps 2 and 3 follow the same path within 6 cm (PX4 flight log).

Watch the demo

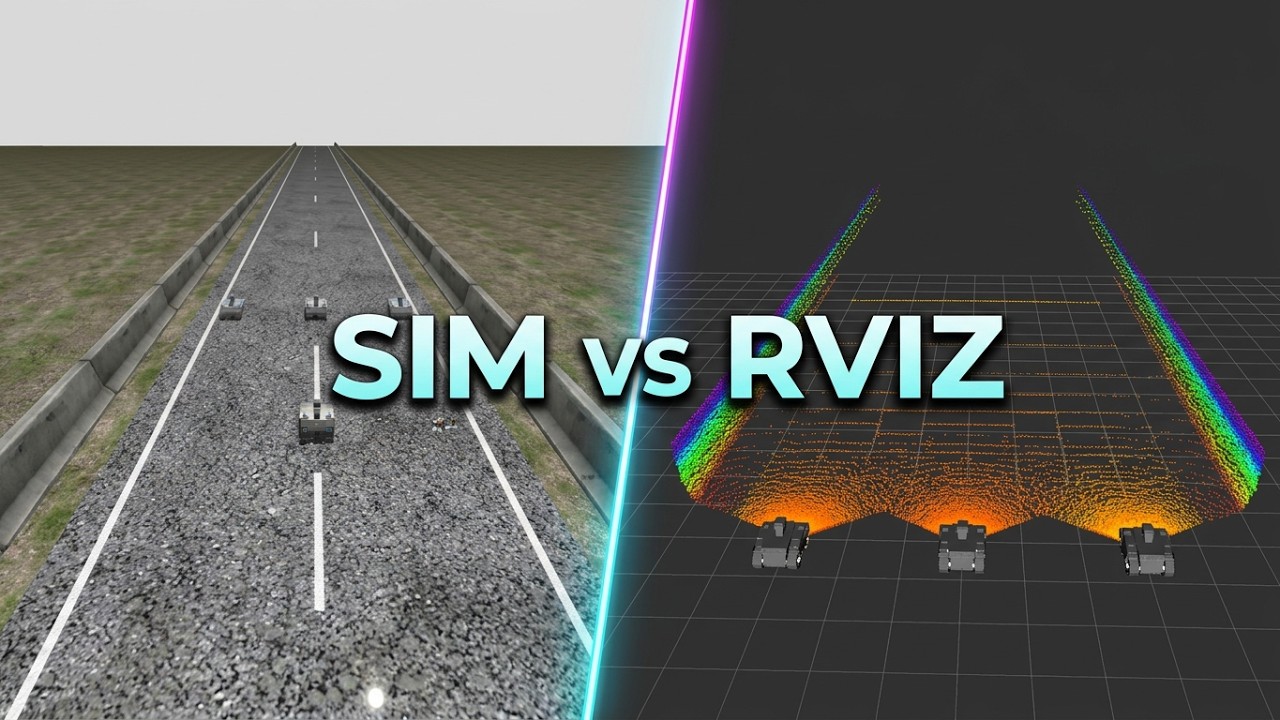
Mengabot

Mengabot

Robotics Simulation ROS 2 Gazebo Harmonic

A modular multi-robot simulation platform: robot models, worlds and fleets configured from a single ROS 2 launch command.

Scale: up to 8 robots at once, each with 3D LiDAR, IMU, GPS and cameras.

Watch the demo

Freelance work

Upwork

I take freelance projects and work remotely with clients and teams anywhere. Client projects are listed on my Upwork profile; client code stays private.

Latest videos

Skills

Area Skills
Computer Vision / Perception Object detection Multi-object tracking Kalman filter YOLOv8 ONNX Runtime
SLAM and State Estimation LiDAR SLAM Sensor fusion Pose-graph optimization Kalman and particle filters
Robotics ROS 2 Nav2 PX4 MAVROS ArduPilot
Simulation Gazebo
Systems C++ Python Docker Linux Git

Pinned Loading

  1. stretch_ai stretch_ai Public

    Forked from hello-robot/stretch_ai

    Embodied Intelligence for stretch robot by hello-robot

    Python

  2. stretch_ros2 stretch_ros2 Public

    Forked from hello-robot/stretch_ros2

    ROS 2 packages for the Stretch mobile manipulators from Hello Robot Inc.

    Python

  3. EasyNavigation EasyNavigation Public

    Forked from EasyNavigation/EasyNavigation

    C++